--- license: mit language: - en tags: - robotics - vision-language-action - world-model - embodied-ai - flow-matching ---
Magic-W0 # Magic-W0: A Structured World–Action Foundation Model for Physical Intelligence *Magic-Lab Team · Magiclab Robotics Inc.* Project Homepage Code Repository Model weights coming soon
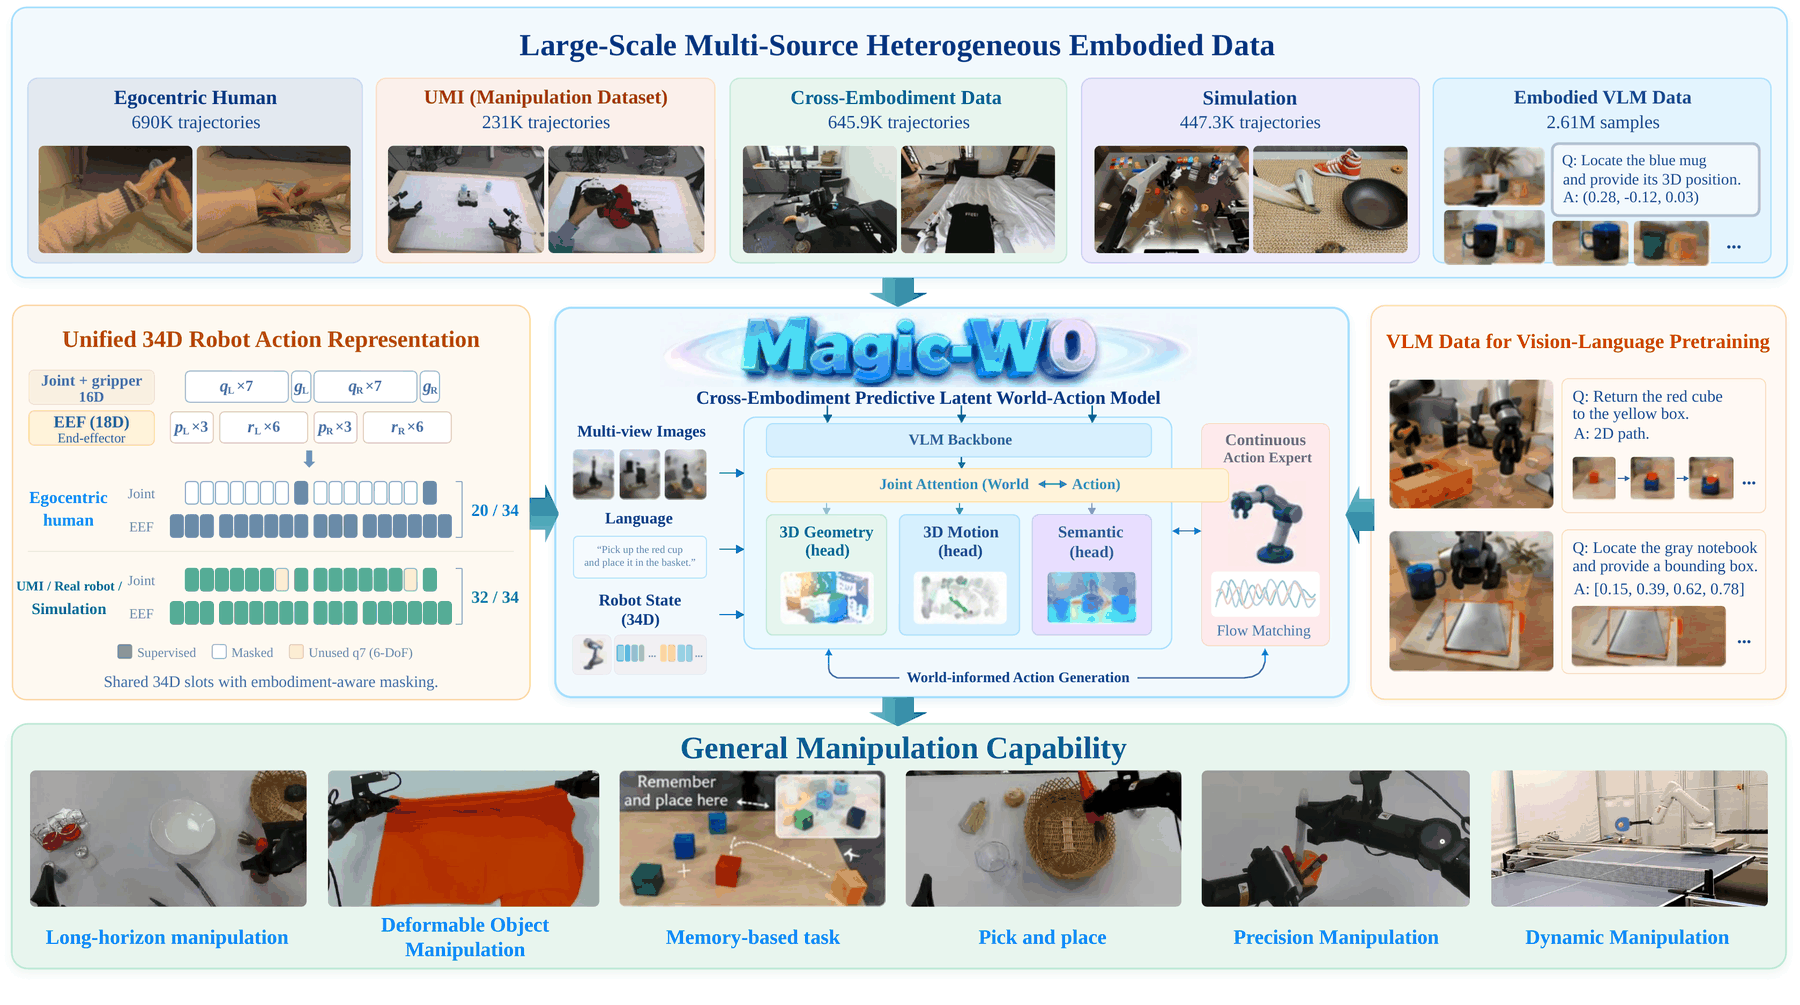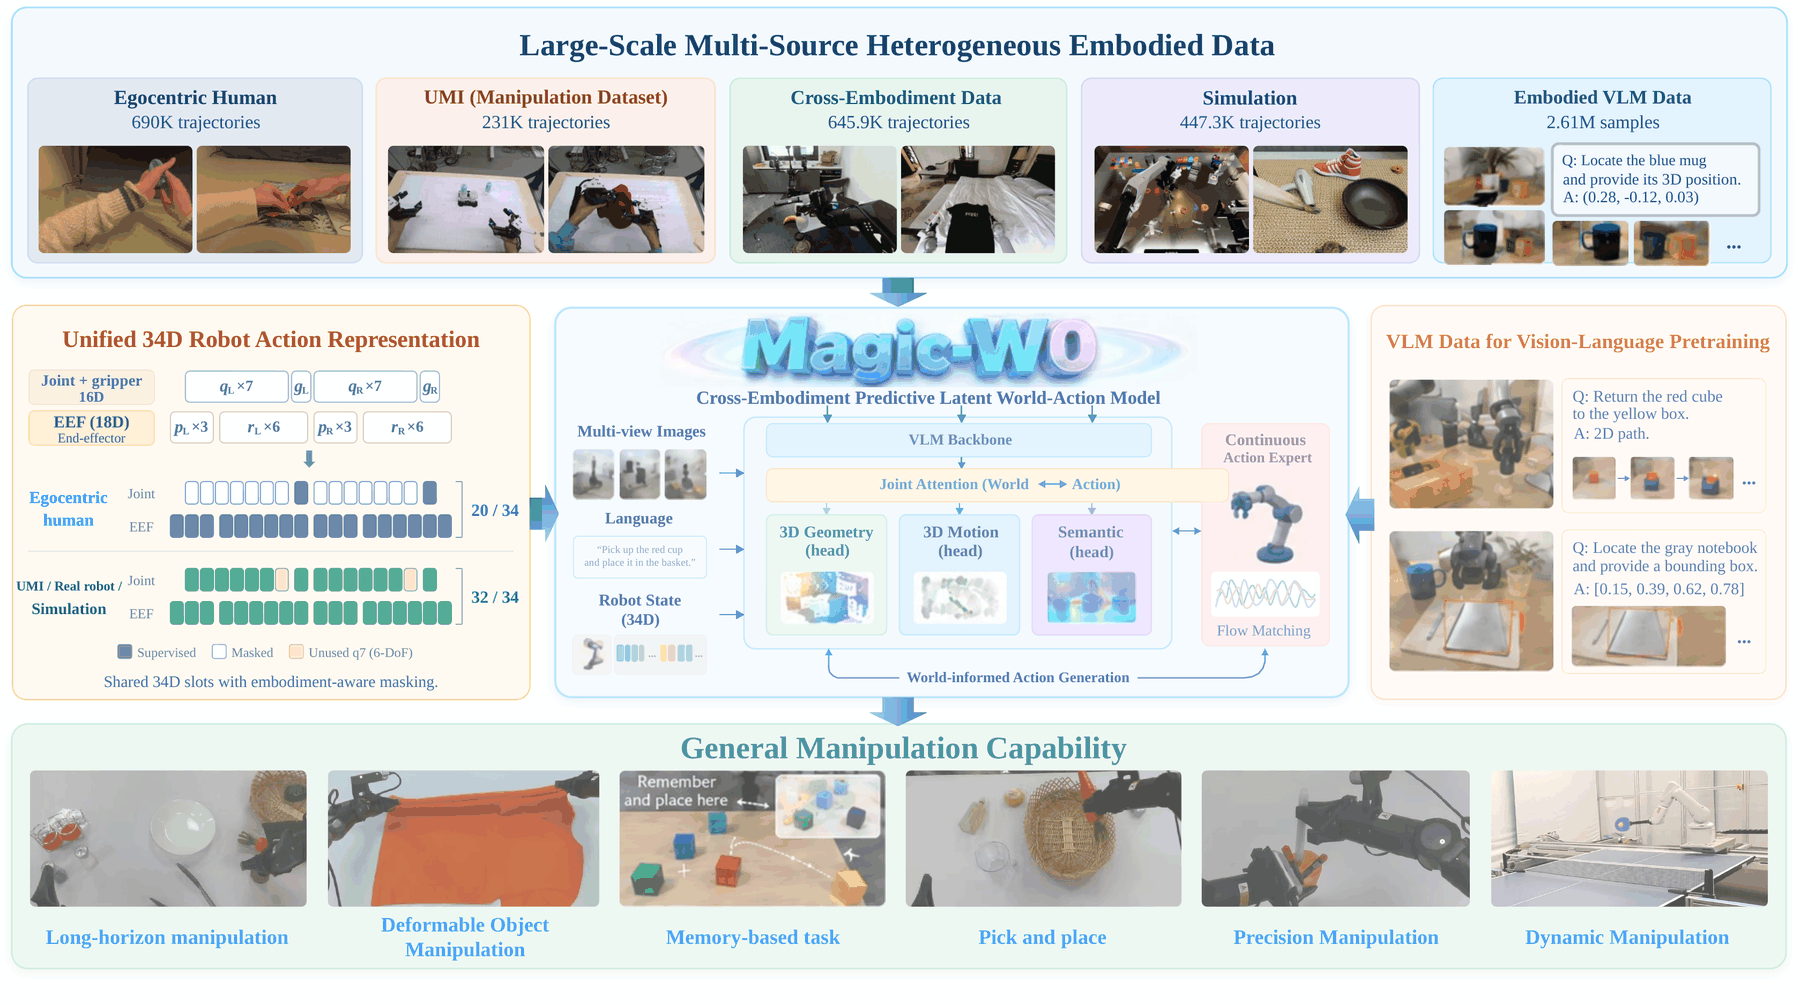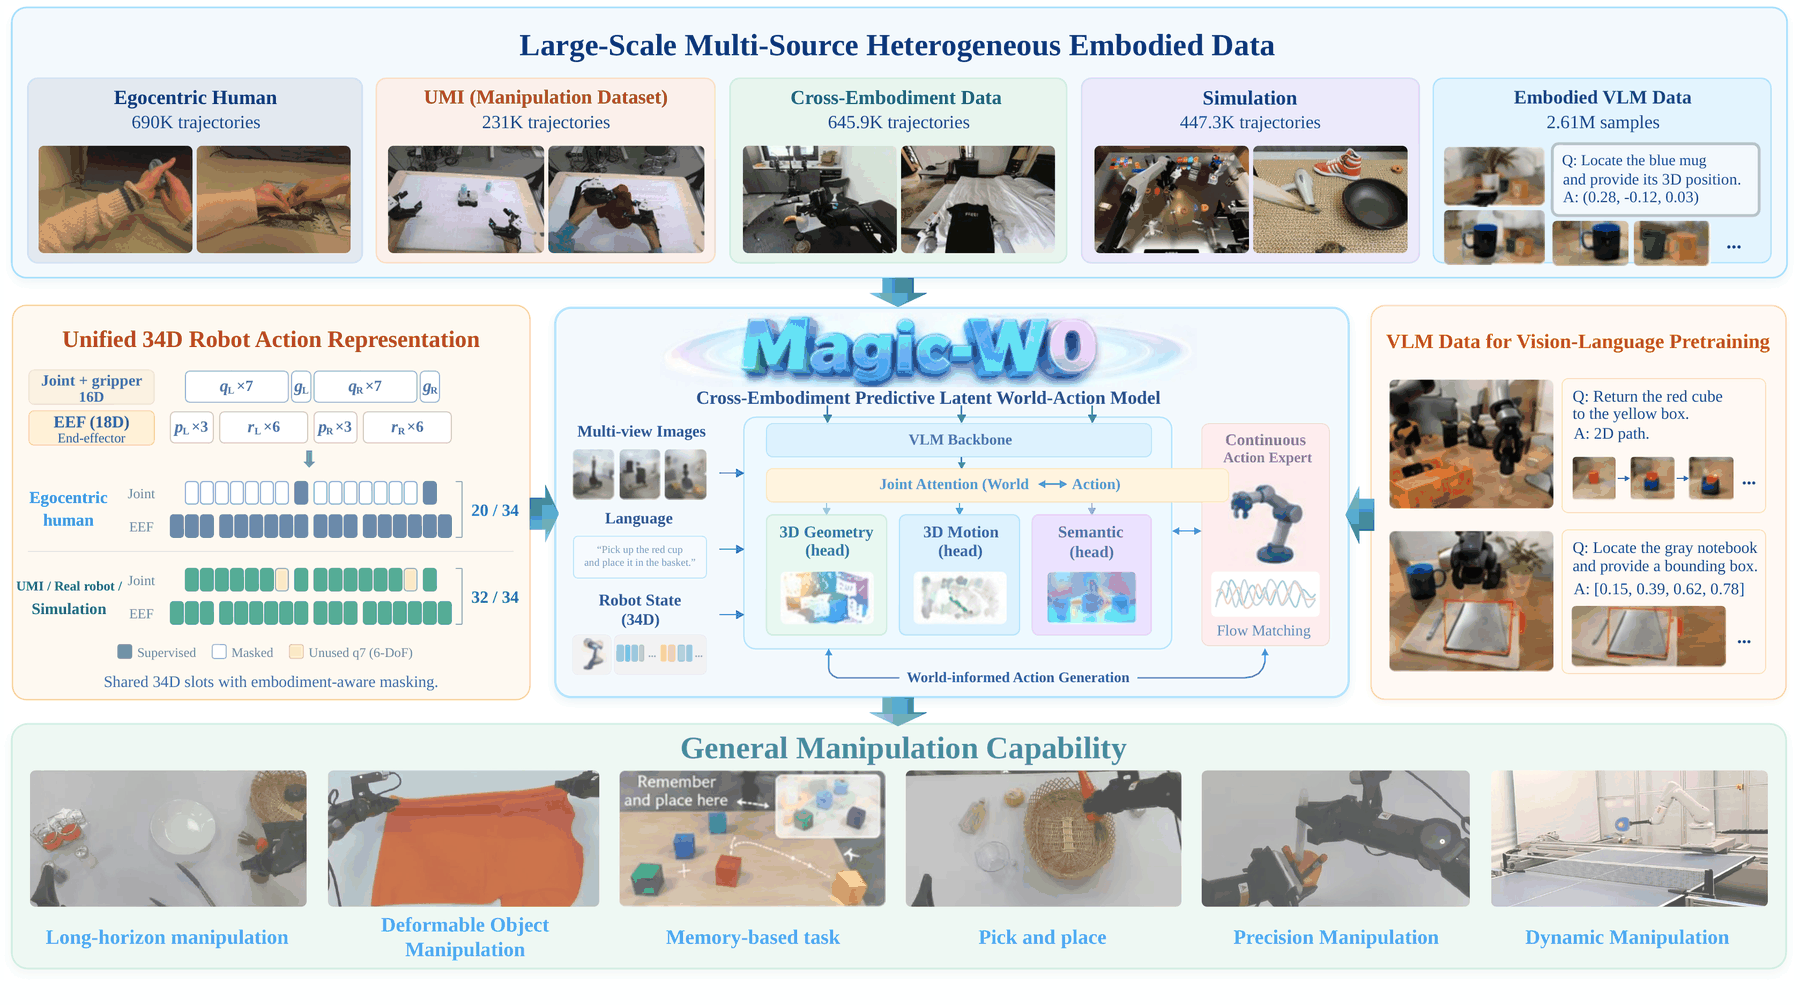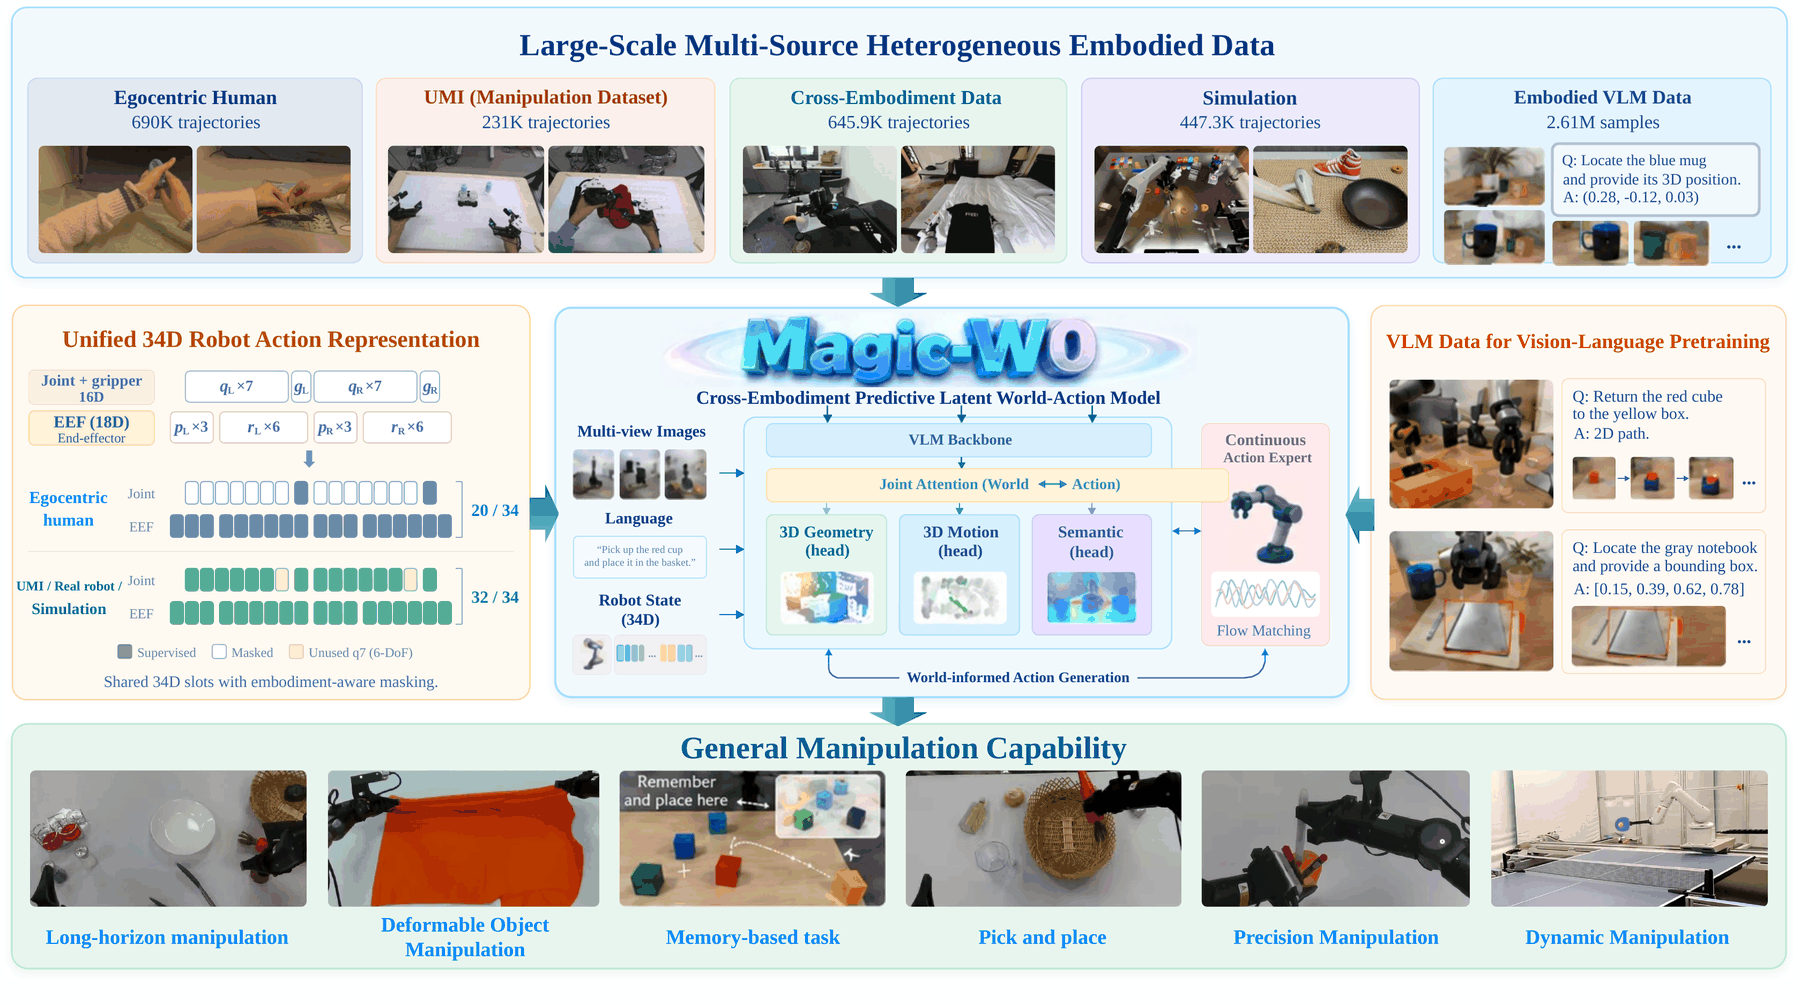
## Abstract Magic-W0 jointly learns structured world transitions and continuous robot actions from diverse embodied experience. By coupling geometry, motion, and future semantics with action generation, it connects physical world modeling with robotic manipulation.

Magic-W0 overview: diverse embodied data, a unified action interface, structured world modeling, and robot manipulation

## Key Features - **World–action modeling:** jointly learn geometry, motion, future semantics, and continuous actions. - **Cross-embodiment learning:** combine human, UMI, real-robot, and simulation experience. - **Teacher-free inference:** use world-model supervision during training without running teachers at deployment. ## Model Weights **Coming soon.** Model weights are not yet available. ## Resources - [Project homepage](https://embodied.magiclab.top/works/wam/magic-w0/index.html) - [Code repository](https://github.com/MagiclabRobotics/Magic-W0) - [Model repository](https://huggingface.co/Flyfish101/Magic-W0)